clover2 documentation
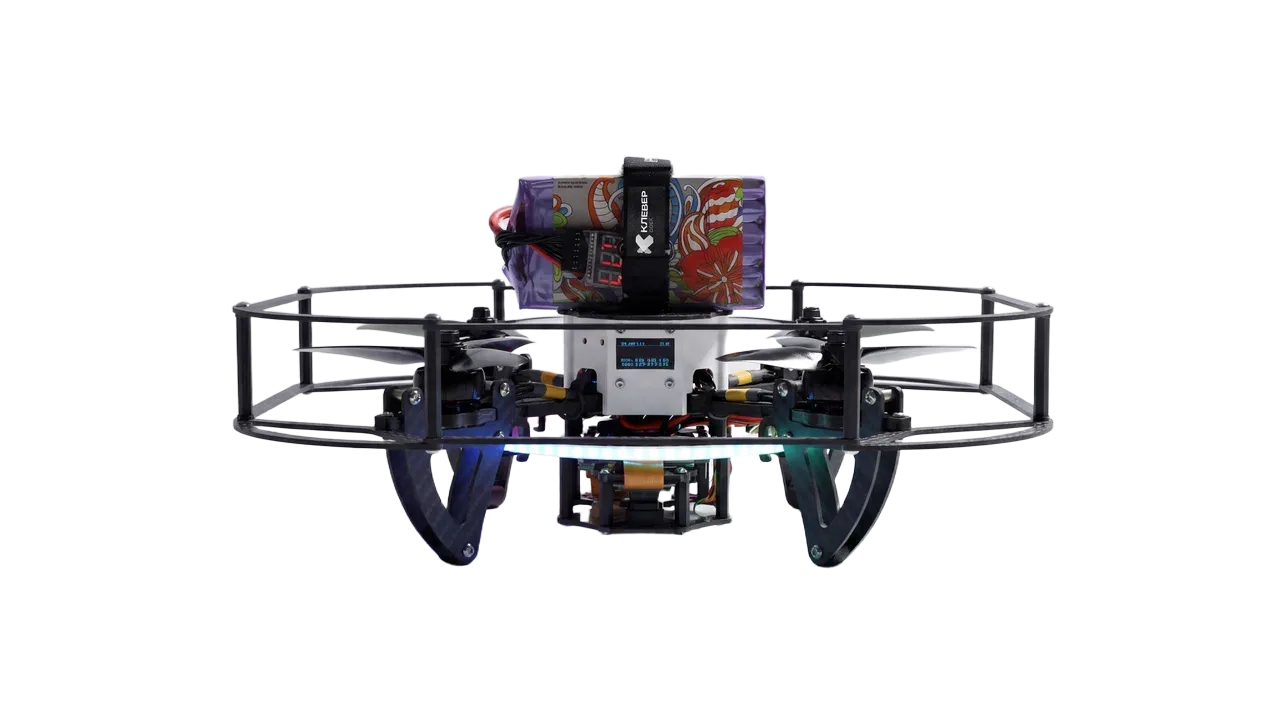
Klever 5 CODE
Klever is an educational quadcopter kit engineered with industry standards in mind. The kit provides everything required for assembly, configuration, and advanced autonomous operation.
Combining modern hardware and cutting-edge software stack, the platform features a high-performance STM32H7-based flight controller running PX4 firmware, ensuring high computational stability for complex control algorithms. Raspberry Pi 5 serves as an onboard computer for ROS 2 nodes, computer vision, and custom user applications.
The upgraded Klever is optimized for the modern robotics ecosystem:
ROS 2: Building scalable, distributed, and reliable control systems.
Docker: Ensuring environment isolation and seamless deployment.
Pre-built containers and project templates: Immediate start.
Open source: Complete transparency with open-source code for customization and study.
Whether you are a beginner or an expert, Klever scales with you. Beginners can bypass complex setups using the preconfigured Raspberry Pi images and detailed documentation. Experienced developers can leverage the platform as a robust foundation for autonomous navigation, computer vision, swarm intelligence, and applied robotics research.
The kit includes a fully configured Raspberry Pi image with all necessary software, libraries, and development tools. Learn more on GitHub.
Getting Started
To begin your journey with the quadcopter kit, refer to the following guides:
Assembly Guide: Everything you need to know to put your kit together.
Setup Guide: Easy steps to calibrate and configure your device.
Development Guide: Get connected and start your first programming project.
Project Insights:: Learn more about the tech behind
clover2.